Faculty: Dr. Jaemin Lee
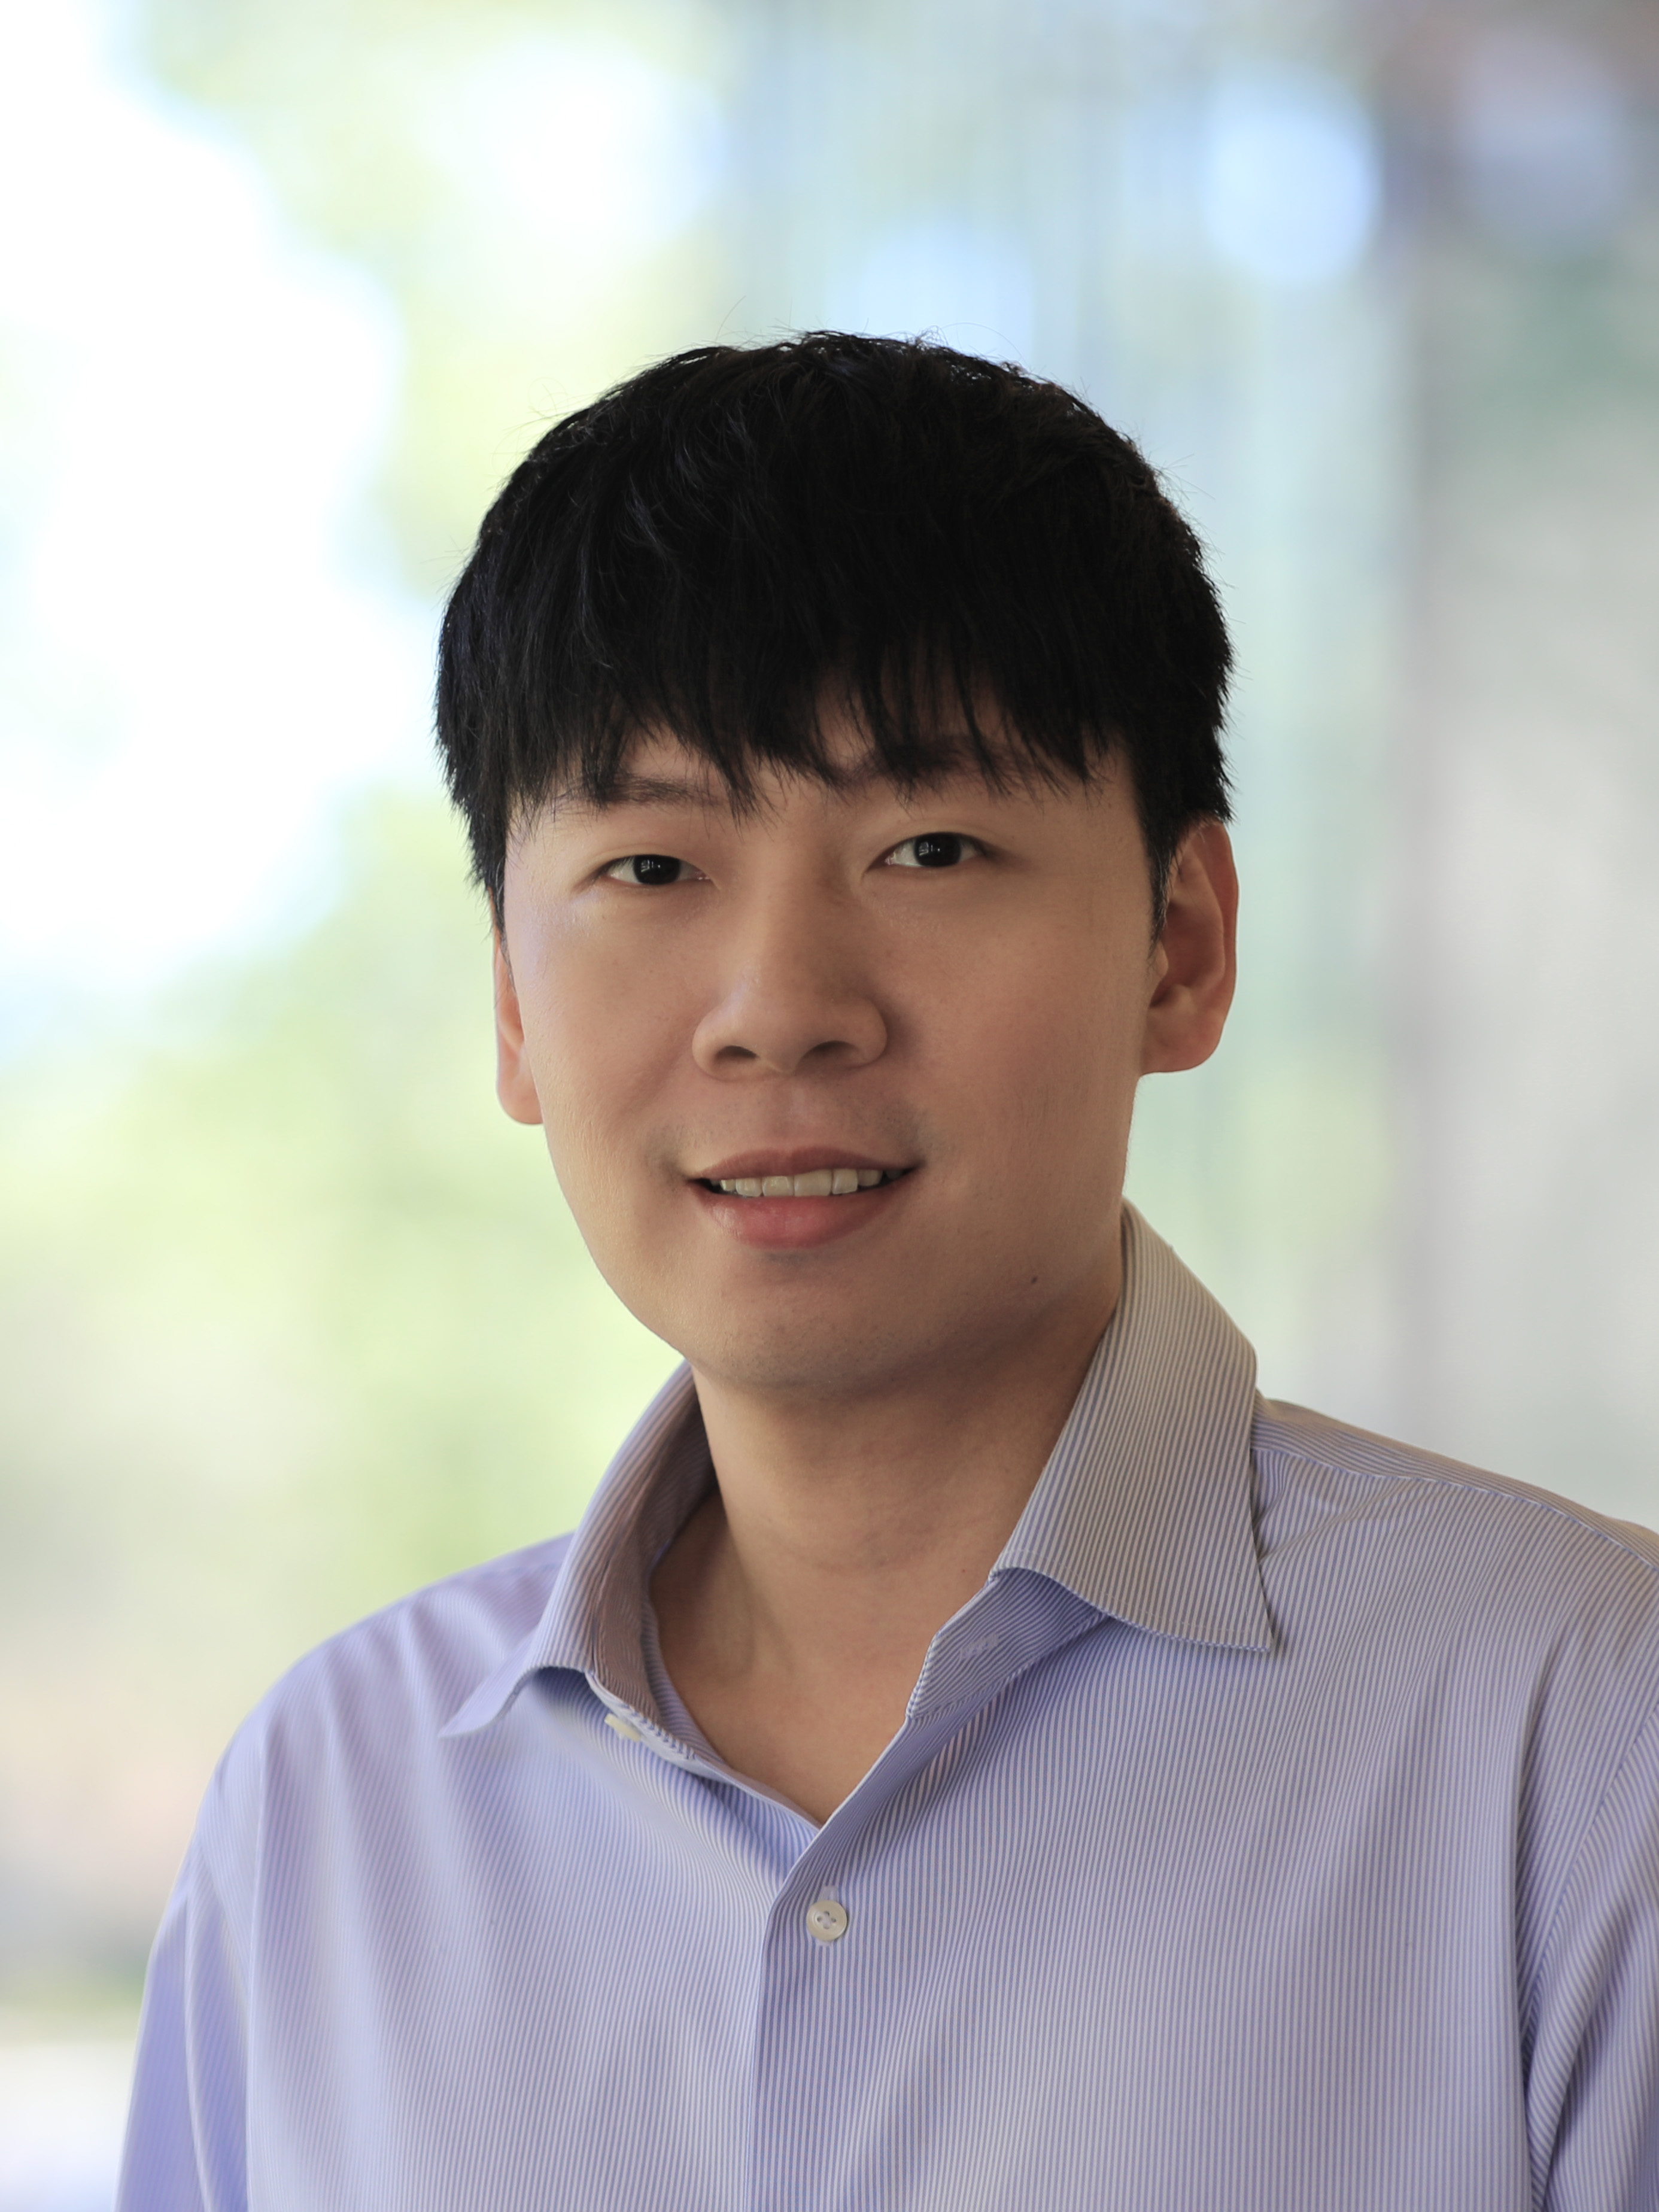
🎓 Academic & Professional Experience
• Assistant Professor (2024 – Present), Department of Mechanical and Aerospace Engineering, North Carolina State University, NC
• Associate Faculty (2025 – Present), Joint Department of Biomedical Engineering, UNC–Chapel Hill and NC State University, NC
• Postdoctoral Scholar (2022 – 2024), California Institute of Technology (Caltech), CA
• Ph.D. in Mechanical Engineering / Robotics (2016 – 2022), The University of Texas at Austin, TX
• Research Scientist (2013 – 2016), Korea Institute of Science and Technology (KIST), South Korea
🏛️ Professional Service & Leadership
• Faculty Member, NC State Robotics Steering Committee (2025 – Present)
• Associate Faculty Member, xGI Initiative, NC State University (2026 – Present)
• Associate Editor, IEEE Robotics and Automation Letters (IEEE RA-L) (2024 – Present)
• Associate Editor, IEEE International Conference on Robotics and Automation (ICRA) (2024 – Present)
Members
JunYoung Kim (Ph.D. Student)
• M.S., Hanyang University, Korea
• B.S., Hanyang University, Korea
• Visiting, UCLA, CA CA
• Research Intern, KIST, Korea
• Topic: Whole-body control for Locomanipulation of humanoids

Anh Tung (Tony) Ho (Ph.D. Student)
• M.S., Stony Brook University, NY
• B.S., KAIST, Korea
• Research Intern, VinMotion, Vietnam
• Research Intern, LG Electronics, Korea
• Topic: Morphology-aware Interactive Humanoid Manipulation

Jingxi Lu (Ph.D. Student)
• M.S., University of Southern California, CA
• B.S., Hong Kong Baptist University, China
• Visiting, Georgia Tech, GA
• Topic: Fault-aware Safe Learning for Humanoid Locomanipulation

Hanbin (Ethan) Jang (Ph.D. Student)
• B.S., Seoul National University, Korea
• Visiting, North Carolina State Unversity, NC
• Topic: Context-aware Adaptive Framework for Long-horizon Robotic Tasks
Andrea Basuroski (M.S. Student)
• B.S., North Carolina State University
• Topic: Transformable robots
David Alexander (M.S. Student)
• B.S., North Carolina State University
• Topic: Hybrid control for manipulators
Rae E. Heinzerling (M.S. Student)
• B.S., North Carolina State University
• Topic: Active Vision using an Eye-in-Hand Camera
Craig Bowman (M.S. Student)
• B.S., University of North Carolina at Charlotte
• Topic: RL-based Control of Robots
Noah Bowman (UG Student)
• Topic: Perception-guided planning and control
Daimian Gouge (UG Student)
• Topic: Vision-guided hand manipluation
Ian Shub (UG Student)
• Topic: Robot Hardware Design
Matthew Mitchell (UG Student)
• Topic: Robot Control and Design
Eera Singh (UG Student)
• Topic: Robot Hardware Design

Kunsang Gole (UG Student)
• Topic: Robot Hardware Design
Robots

Humanoid G1

Quadruped Go2
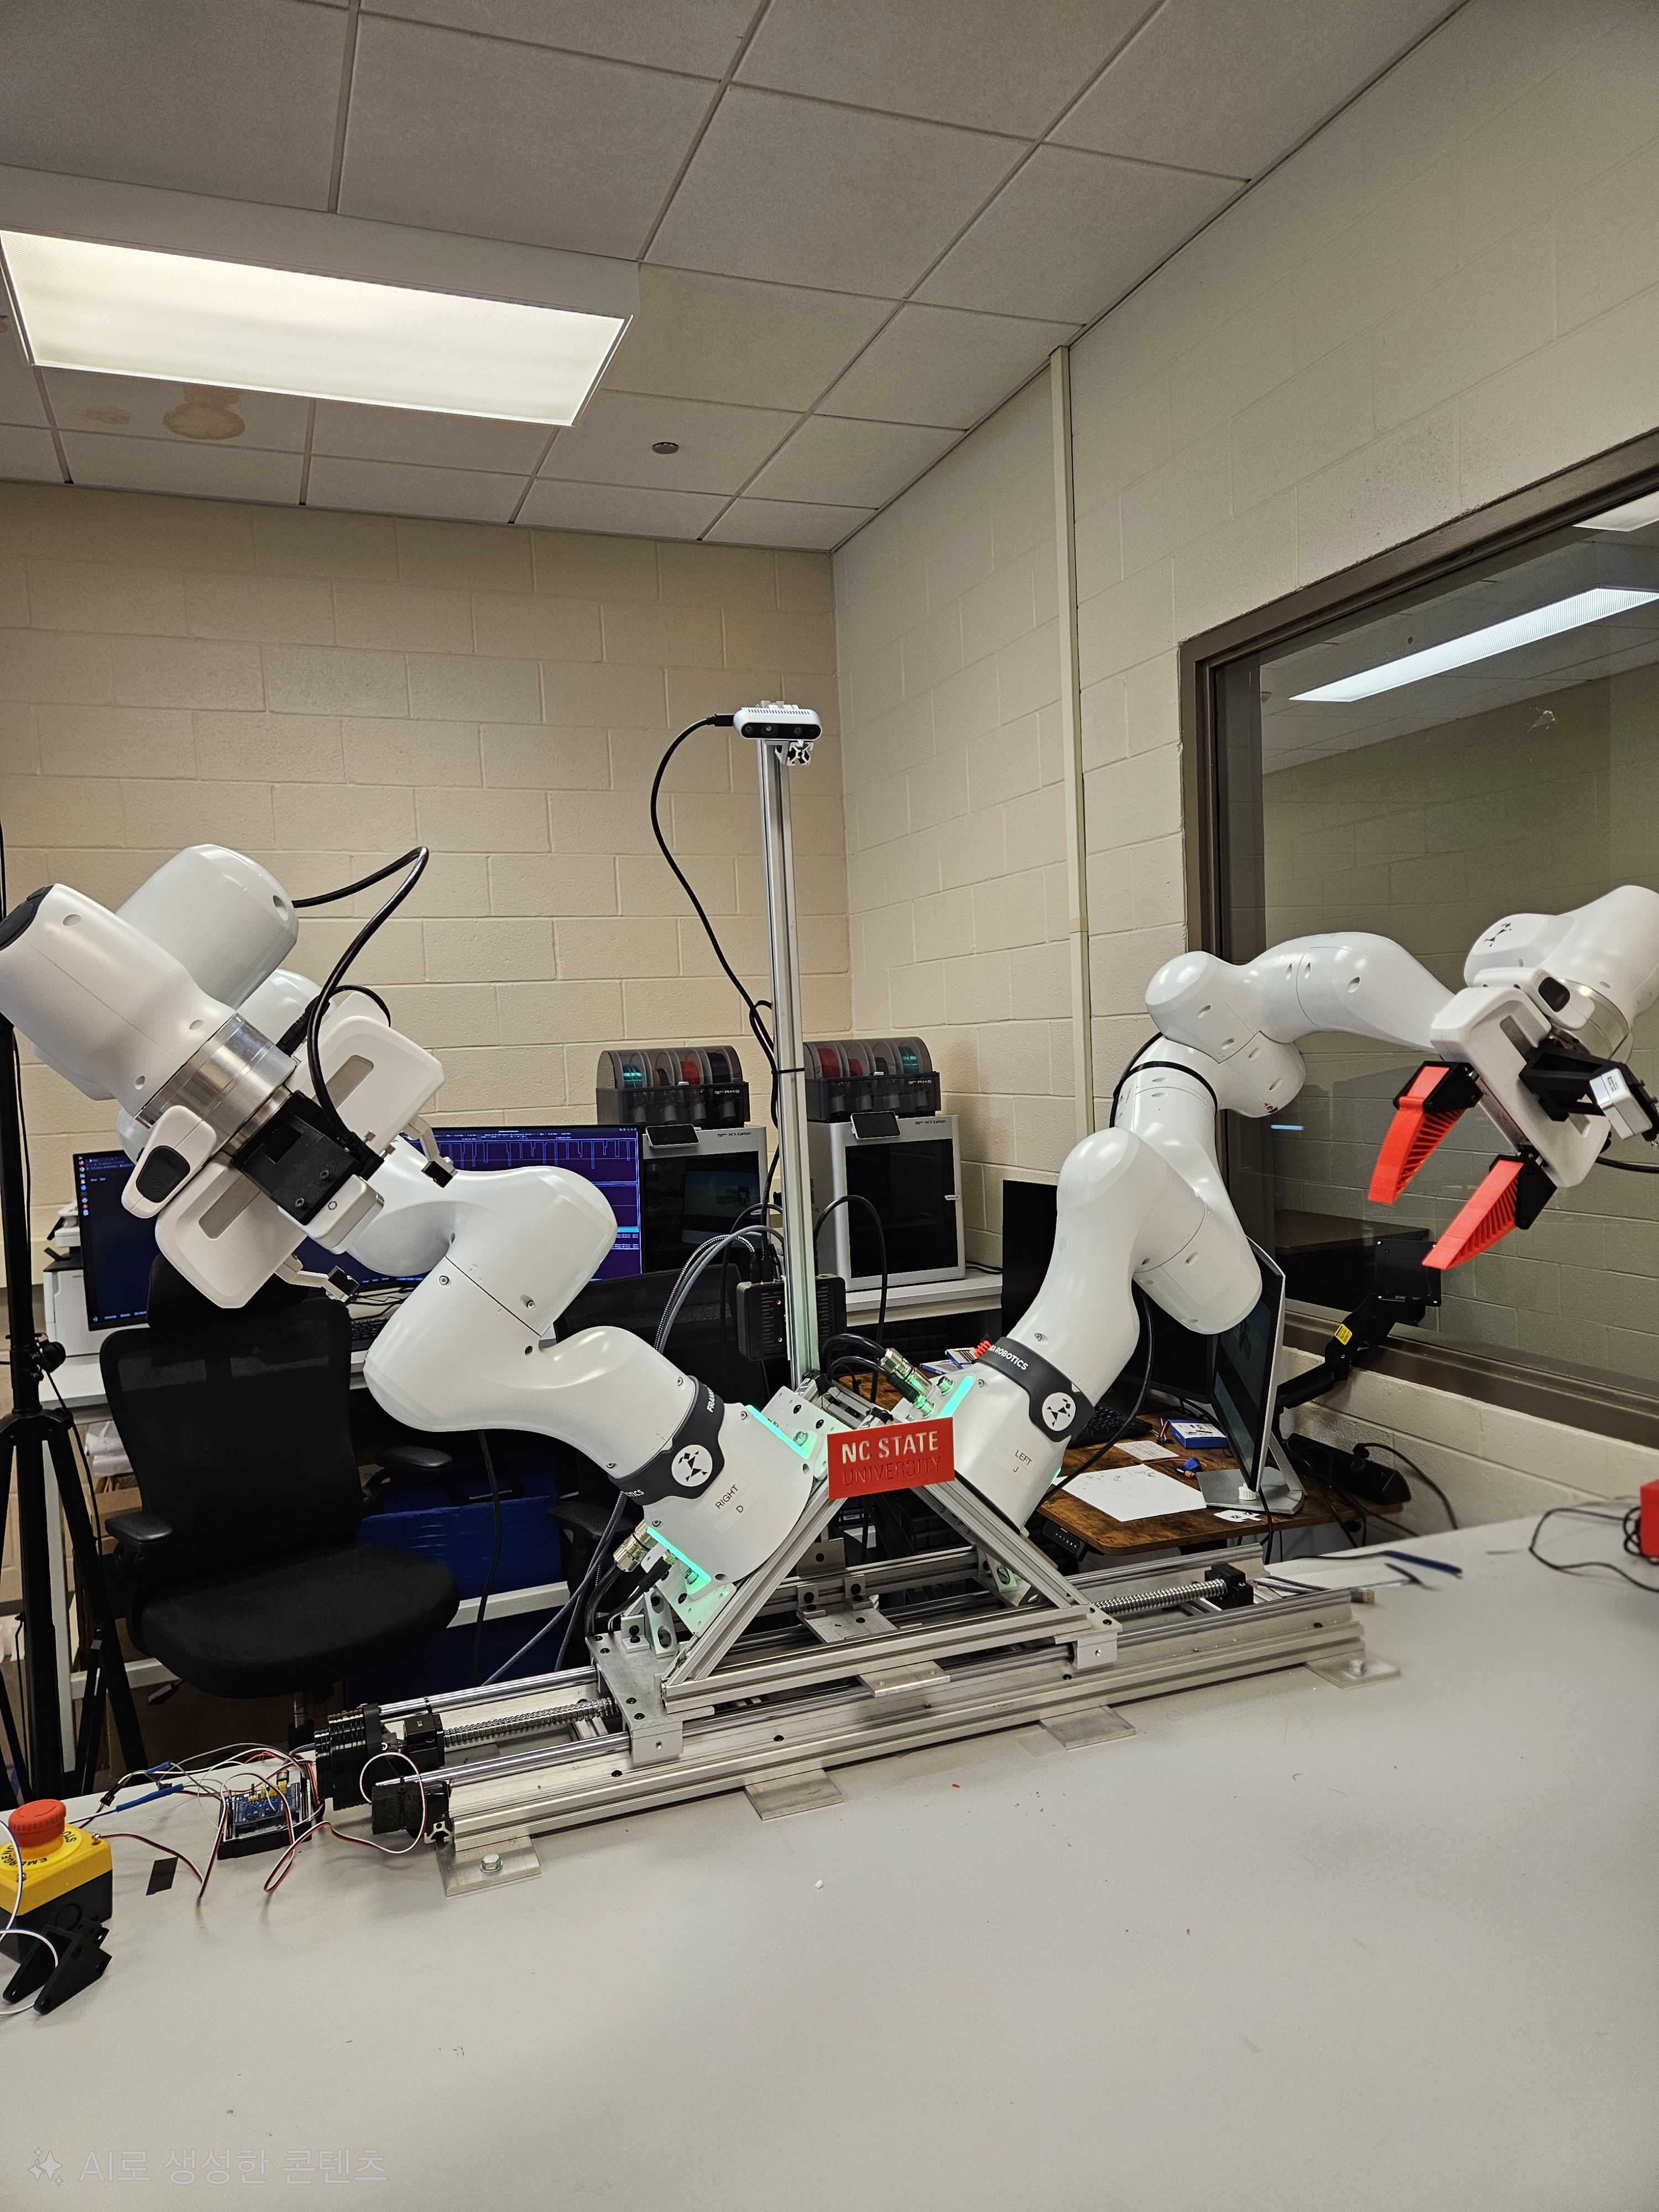
Furanka Arms
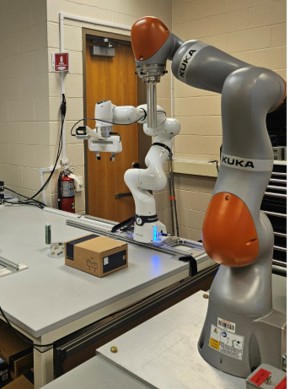
KUKA Arm
Formal Students (Graduate Students)
Sebastian King (2026, M.S., MAE) - Corning Incorporated
Jakub Jon (2025, M.S., Visiting) - Helsing
Formal Students (Undergraduate Students)
Wonho Jung (2026, B.S., Visiting) - M.S. Student, Seoul National University
Hanbin Jang (2025, B.S., Visiting) - Ph.D. Student, HIER Lab, North Carolina State University
Keagan Donovan (2025, B.S., MAE) - Blue Origin
Ali Mohamed-Alie (2025, B.S., MAE) - Air Distribution Technologies, Inc.